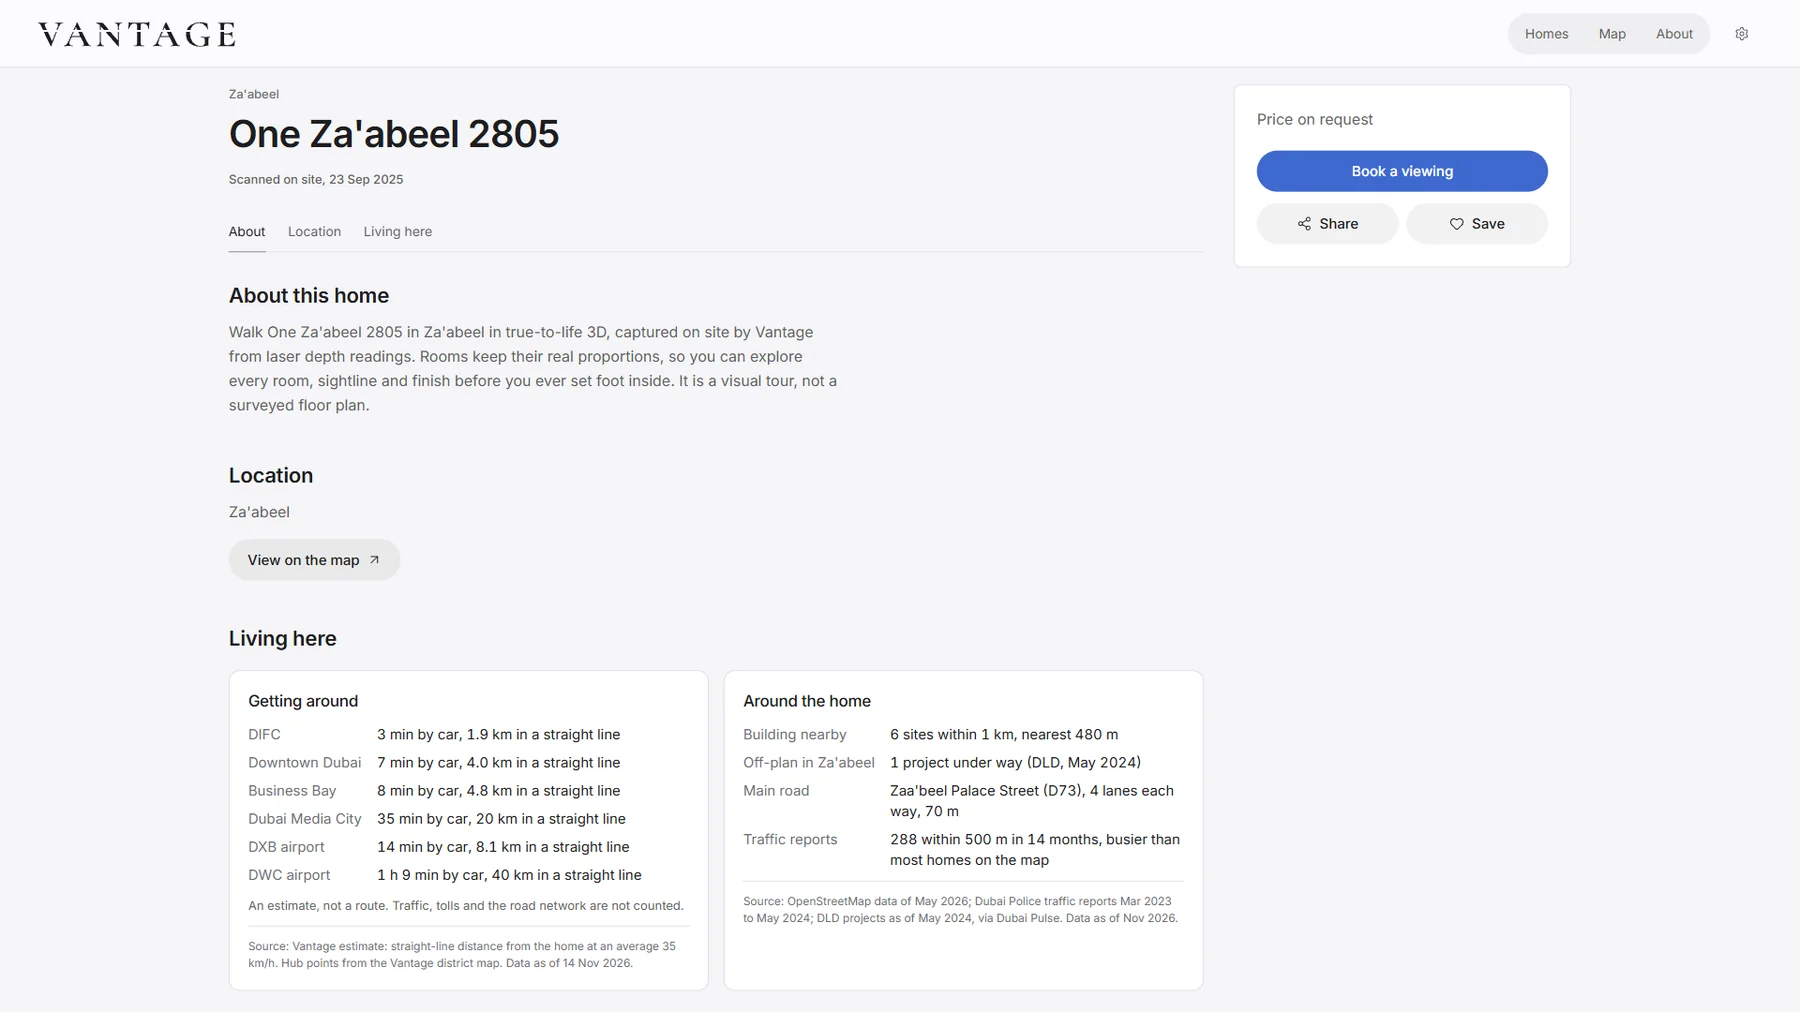
On the line
Two frames from earlier builds
Chapter 01 of 04
The brief
Three tools, one surface.
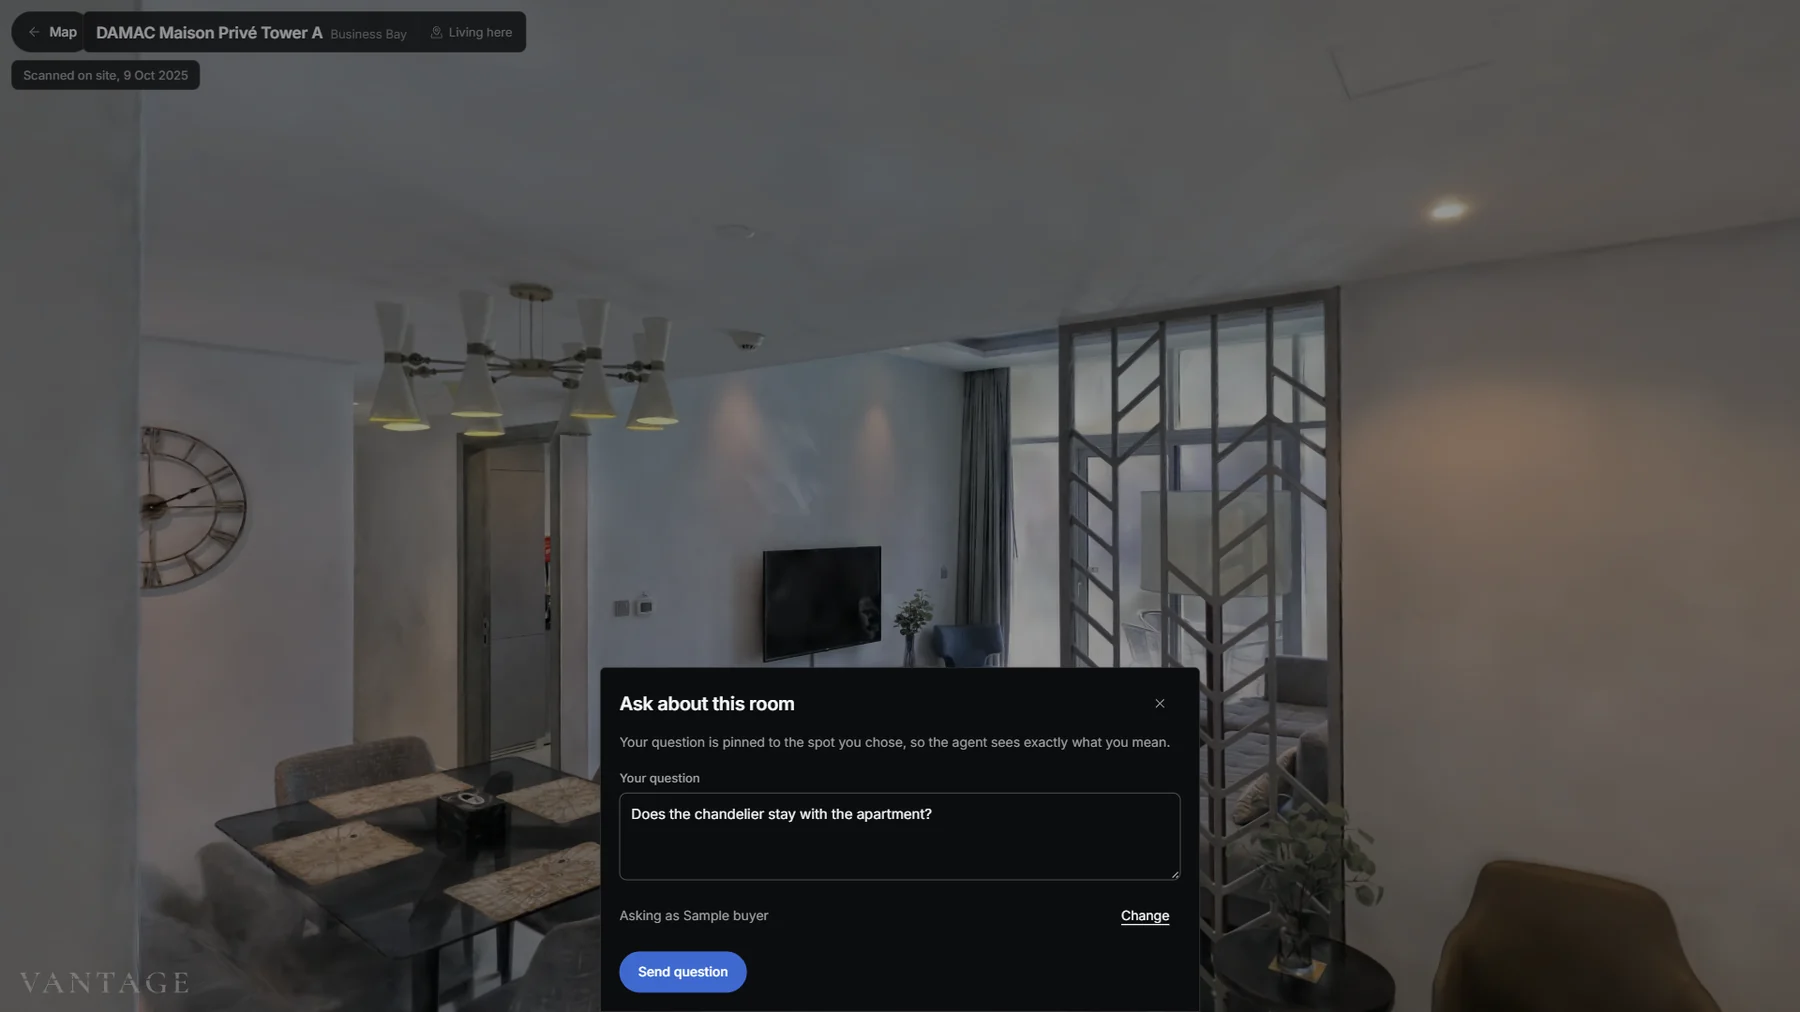
A buyer could walk a real Dubai residence in the browser, or have a broker drive the same walkthrough live while they followed on their own device.
Three broker tools already existed at BARNES Dubai: the marketplace of curated listings, the scan viewer shipped on the property pages, and co-browse. They lived in separate apps, and every switch between them lost the thread.
- 1Marketplace
- 2Scan viewer
- 3Co-browse
- 4One platform. One object per residence.
Vantage became one surface with modes rather than three separate apps. The listing a broker shows and the residence they walk are the same object, one click apart.
Chapter 02 of 04
The scans
Published under the Verified by Vantage standard.
Every point was a real on-site Gaussian-splat capture, not a render.
Before a scan shipped, it was checked against a written internal standard: coverage, collision, and a spawn point computed from the room's geometry. Only then did it earn a Verified by Vantage badge.
- 1Scan record: a real on-site capture
- 2Coverage
- 3Collision
- 4Spawn point, from the room's geometry
- 5Verified by Vantage
- 6Viewer: the walkable residence, one per listing
A point-cloud minimap replaced floor plans, which misread furniture as walls.
The viewer runs on gaussian-splats-3d, shared with the standalone Splat Viewer through the barnes-scan-viewer package and embedded per residence. A listing drops you straight into the full walk rather than a second app.
Chapter 03 of 04
Co-browse
The broker drives. The client follows.
A broker-led tour needs low-latency camera sync between broker and client. That traffic does not need to leave the infrastructure already hosting the scans.
So the client's browser follows the broker over a self-hosted WebSocket relay, co-located with the splat viewer, not a third-party vendor. There is no recurring realtime-vendor bill, and the stack stays in one place to operate.
- 1Broker drives
- 2camera state, out
- 3WebSocket relay, self-hosted
- 4camera state, relayed
- 5Client follows
- 6Splat viewer
- 7One host: the infrastructure already serving the scans
The relay was put together through trial and error. Checked live: join, presence, camera state and reactions all round-trip correctly.
Chapter 04 of 04
What changed
Map-led, then marketplace-first, then a living map again.
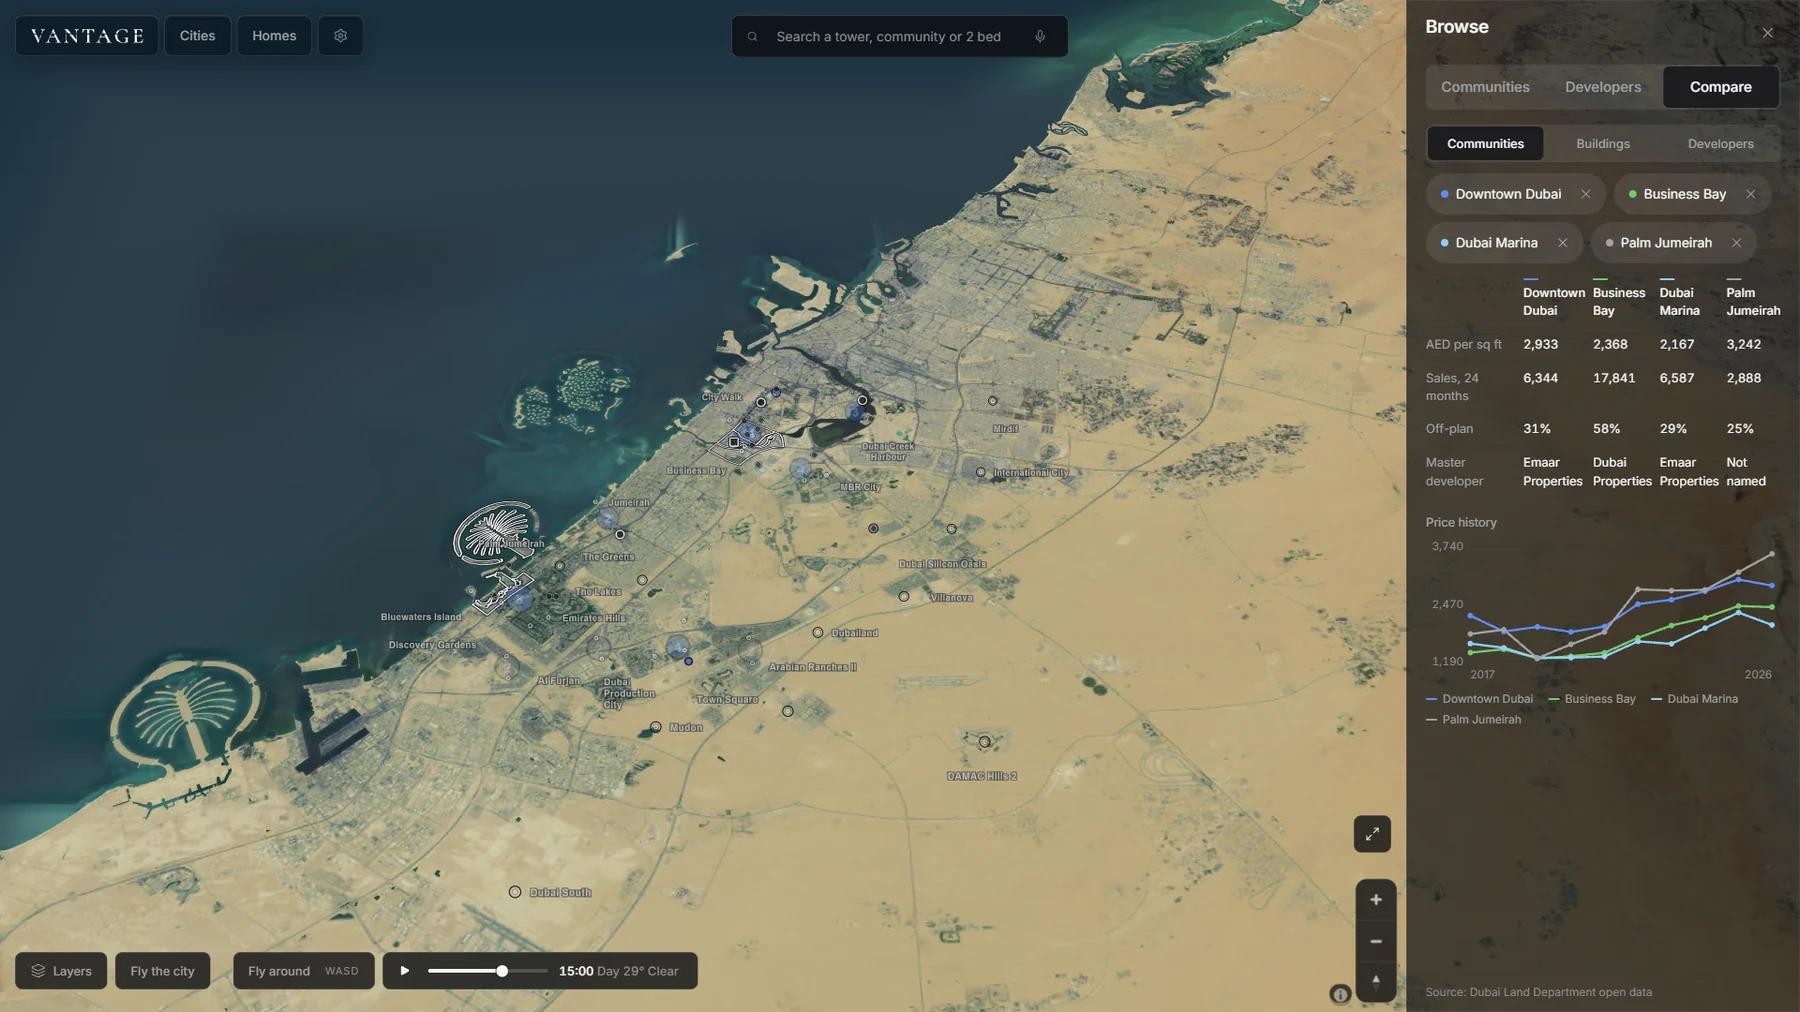
Vantage was map-led through the summer of 2026. It opened on a map, and the first question it answered was what had been scanned near you.
Checked on 2026-09-11, the front door was a redirect to the marketplace. The standalone full-screen map was gone and the scan map had folded into the scan library, with the library and the viewer reached from a listing. Search still ran in plain language.
The consolidation was the decision. The map was only the first surface it landed on.
It ran as a live pilot, not a demo: stress-tested under load, a memory-streaming fix proven live, and every dead button found by checking real fetch calls against real routes, one at a time.
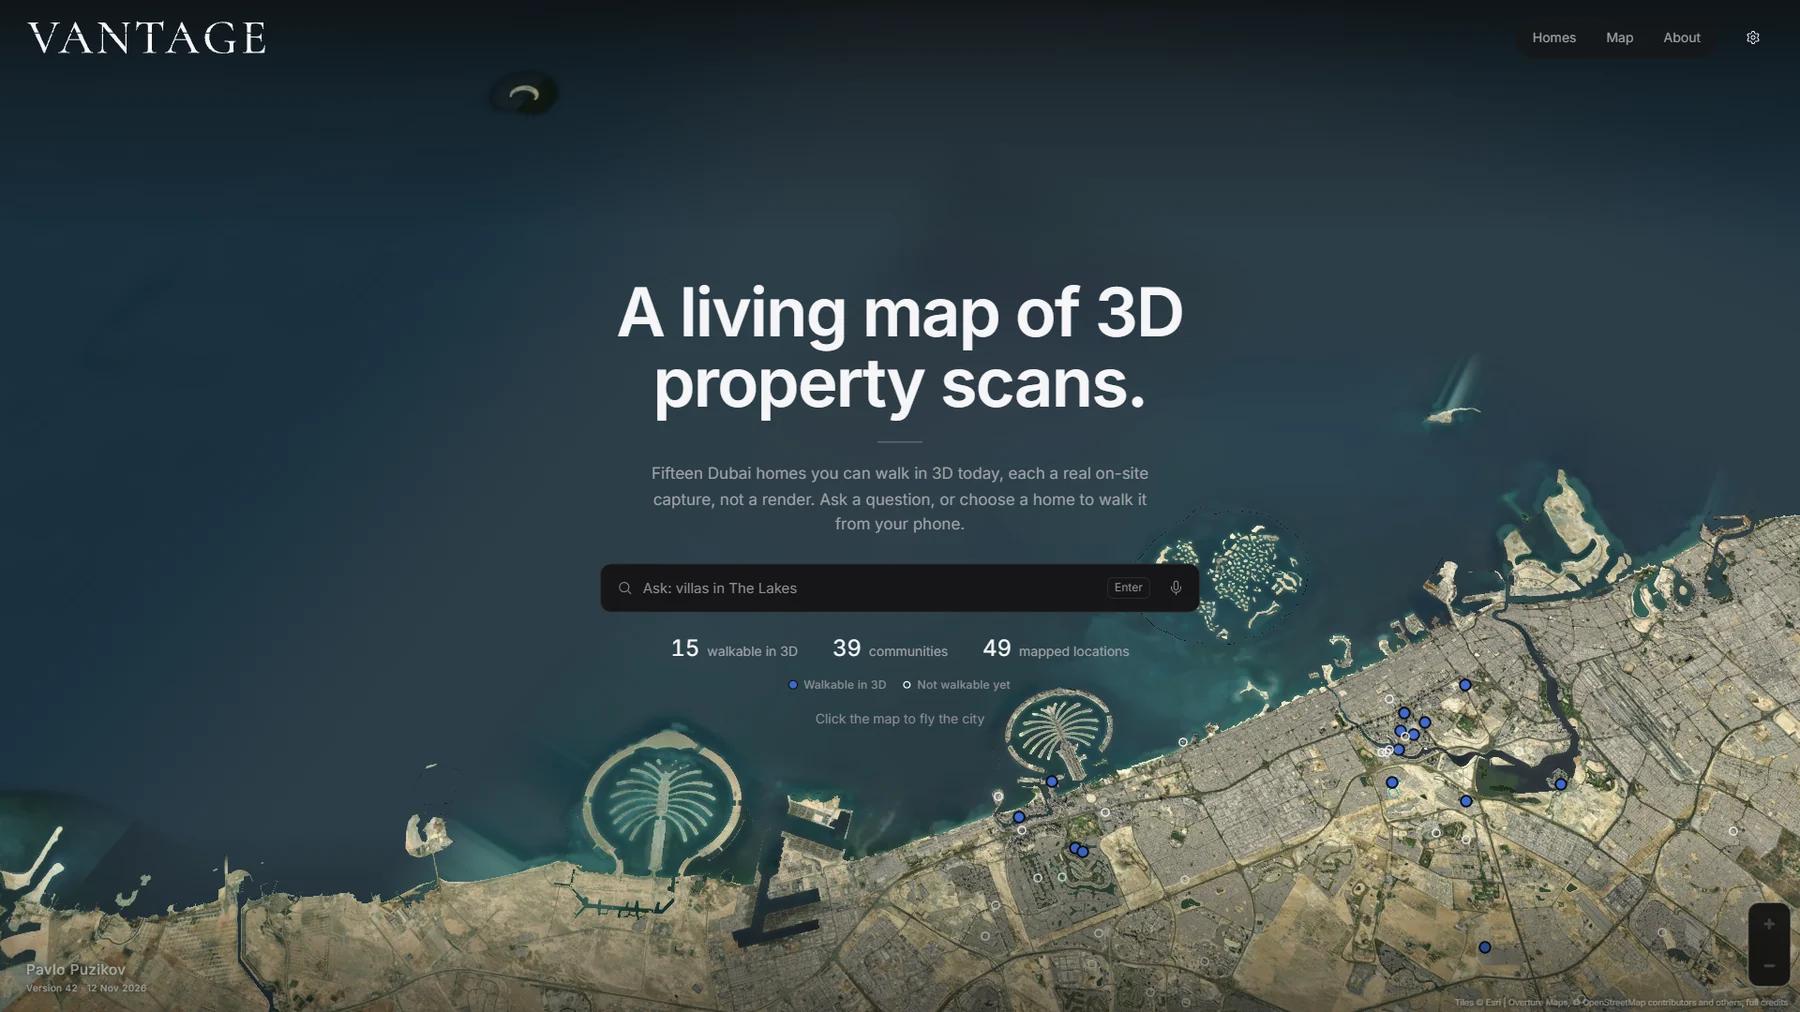
In October and November 2026 I rebuilt it as a map of Dubai with a 3D city model made from open data, and put the scans on their towers. You find a home on the map, see which floor of which tower it is on, then walk through it. Abu Dhabi followed. The city model now has its own page. The home page is that living map again, full screen. The interface was redrawn in November to an Apple-like system: light pages, dark viewers and one blue accent, so the city and the room are the brightest things on screen.